PijpMasterPro6000
A pipe-navigating robot made for the "underground" hackathon hosted by the Robot Student Association in Delft. The team placed second.
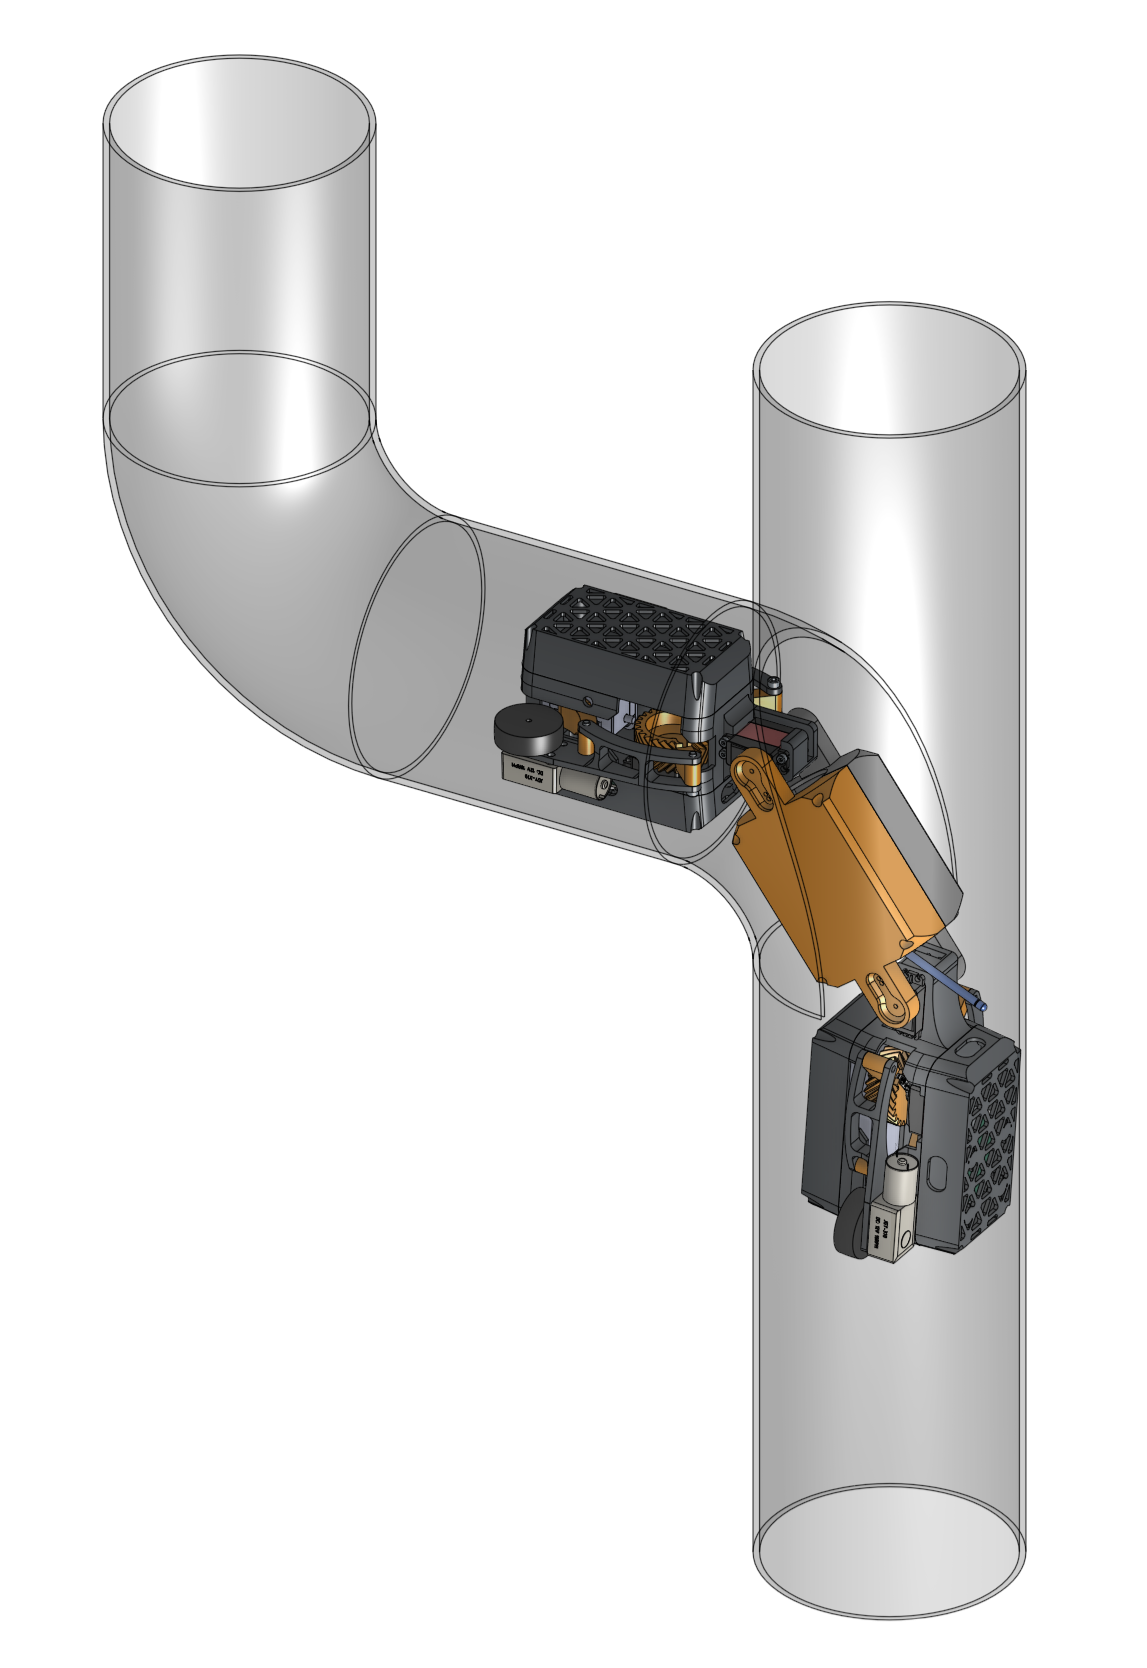
Project Overview
As part of a multidisciplinary project for the “Underground Hackathon” hosted by RSA, we were tasked with developing a robot capable of navigating through pipes. The robot had to navigate a blind maze of vertical sewage pipes using a remote camera module. The task was revealed five days before the hackathon, while the prototype had to be built on the day of the hackathon itself.
Engineering Decisions
3-body Assembly
The robot needed to be able to navigate through a vertical maze of pipes, which required the robot to be able to take corners. The team designed a system consisting of 3 bodies. The front body contained the remote camera module issued to every competing team. The middle body housed an Arduino Mega and an nRF module for remote control, while the rear body contained the battery and motor drivers. The bodies were connected to eachother via hinges that where actuated by heavy-duty 40Kg servomotors. By positioning one body in a different direction, the robot could actively choose its path through a junction while moving either forwards or backwards.
Extendable Wheelsets
To provide sufficient grip while also allowing the robot to negotiate turns, the front and rear bodies were equipped with mechanically extendable wheelsets. To minimise the overall weight and complexity of the robot, each wheelset was actuated by a single servomotor. The servomotor was mounted directly to one of the wheel arms, while the opposing arm was synchronised using a pair of herringbone gears. This allowed both sides of the wheelset to extend and retract simultaneously using a single actuator.
Performance
Our design nearly outperformed the competition and ultimately placed second in the hackathon.